Boring-Run
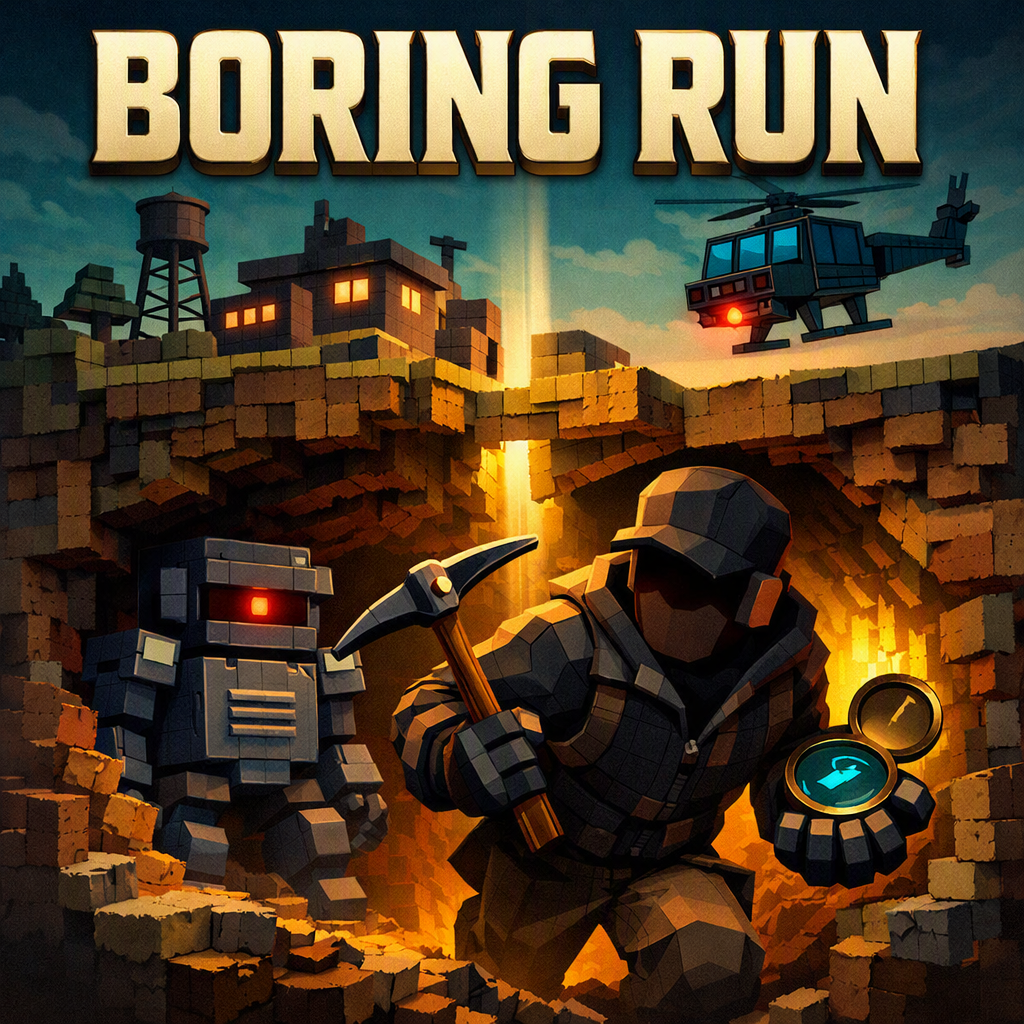
Boring Run
Play at https://www.jabali.ai/game/778d7187-dd70-47d7-849e-382ae4eefda2/create-from-scratch/boring-run/
Your objective
You are a fugitive escaping through a voxel world. Begin at the Starting Point, dig underground, and reach the Destination before capture or seismic timeout.
To win, reach the actual surface within one voxel of the Destination. Being underneath it is not enough. Its marker appears only when you are nearby.
Navigation accuracy comes at a cost: earthquakes move the Destination, while your compass remembers old coordinates. Calibration restores accuracy but summons another robot.
Controls
| Control | Action |
|---|---|
| Mouse | Look around and aim the pickaxe |
| W / A / S / D | Move horizontally relative to your facing direction |
| Hold W while looking more than 45° upward | Move straight up if there is clear headroom; otherwise continue horizontally |
| Hold left mouse | Repeatedly strike a targeted block |
| E | Place a calibration device at an eligible shaft entrance |
| F — Observe Mode only | Toggle camera-directed flight on/off |
| Escape | Pause or resume |
Quick start
- Select Easy for a more forgiving first run. Normal is the default. Leave Observe Mode off if you want to play for a win.
- Click Begin Escape. If the browser does not capture your mouse, click inside the game.
- Look straight down and hold left mouse. Each block takes two hits. Break the first surface block and let gravity lower you into the opening.
- Get at least two blocks deep before five continuous seconds of surface exposure. The first excavated layer is still unsafe. The helicopter captures you if you remain exposed too long, regardless of how far away it is. Getting fully underground resets exposure.
- Your first destroyed surface block schedules a robot after 10 seconds on Easy or 5 seconds on Normal. Dig away from the entry. Robots capture you after two uninterrupted seconds of clear sight. Turn a tunnel corner or put solid terrain between you and the robot to reset detection. Watch the eye icon and danger countdown.
- Follow the compass toward the Destination. When an earthquake occurs, the Destination moves but your compass does not receive its new position. Its arrow can lead to the old location and has additional directional error.
- When you need a reliable fix, dig an upward shaft that reaches the surface, with at least two cleared cells beneath its opening. Approach the shaft entrance until the calibration prompt appears, then press E to place a device. Opening a hole alone does not calibrate.
- Successful calibration updates both compasses to the Destination's current position and clears directional error. It also summons another robot after the difficulty delay. Leave the shaft promptly and avoid lingering in its exposed top layer. Each shaft can be calibrated once; you have six devices.
- Continue toward the refreshed arrow and use tunnel corners to stay out of sight. Choose calibration when its information is worth another patrol rather than automatically using a device after every quake.
- Reach the surface within one voxel of the Destination to escape. Plan your final ascent carefully: the surface exposure timer starts again when you emerge, and the accelerating earthquakes eventually end the run.
Leave a comment
Log in with itch.io to leave a comment.